


Research on normal alignment method for working surface of building drilling robots based on 3D vision
-
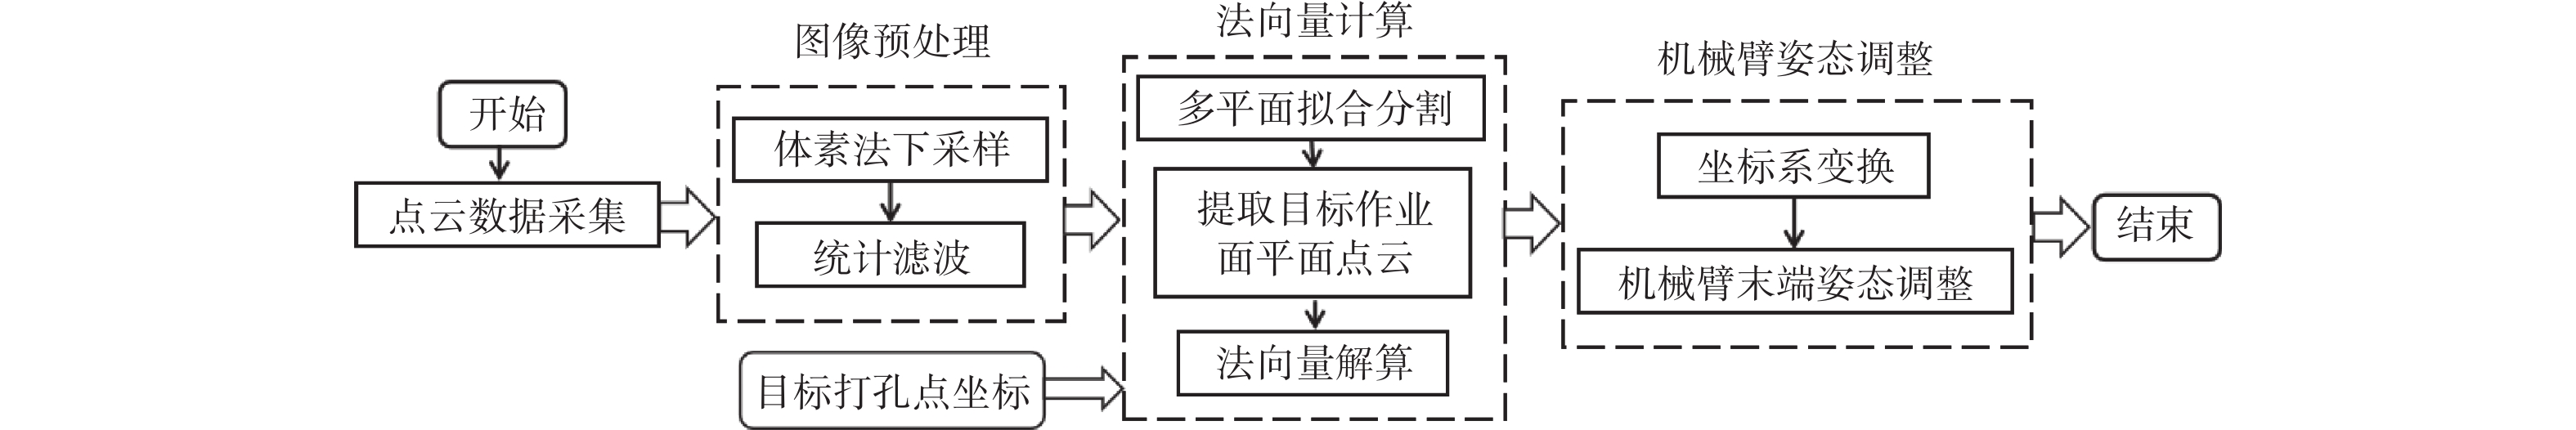
摘要: 为适应在非结构化复杂建筑环境下机器人作业规划、定位等关键问题,提出一种基于3D视觉引导的建筑打孔机器人作业面法向找正方法,建立法向找正测量系统及流程,对采集的作业区域点云进行预处理,并基于随机采样一致(random sample consensus, RANSAC)算法进行多平面拟合分割,根据已知目标打孔点确定目标作业面及其法向量,引导机械臂工具末端调整作业姿态。试验结果表明,该方法解算的法向量角度误差可控制在±3°以内。Abstract: To address key issues such as robot operation planning and positioning in unstructured and complex building environments, a normal alignment method for the working surface of building drilling robots guided by 3D vision was proposed. A normal alignment measurement system and workflow were established. The point cloud of the collected working area was preprocessed, and multi-plane fitting and segmentation were carried out based on the random sample consensus (RANSAC) algorithm. The target working surface and its normal vector were determined according to the known target drilling points, so as to guide the end of the robotic arm tool to adjust the working posture. Experimental results show that the angular error of the normal vector calculated by this method can be controlled within ±3°.
-
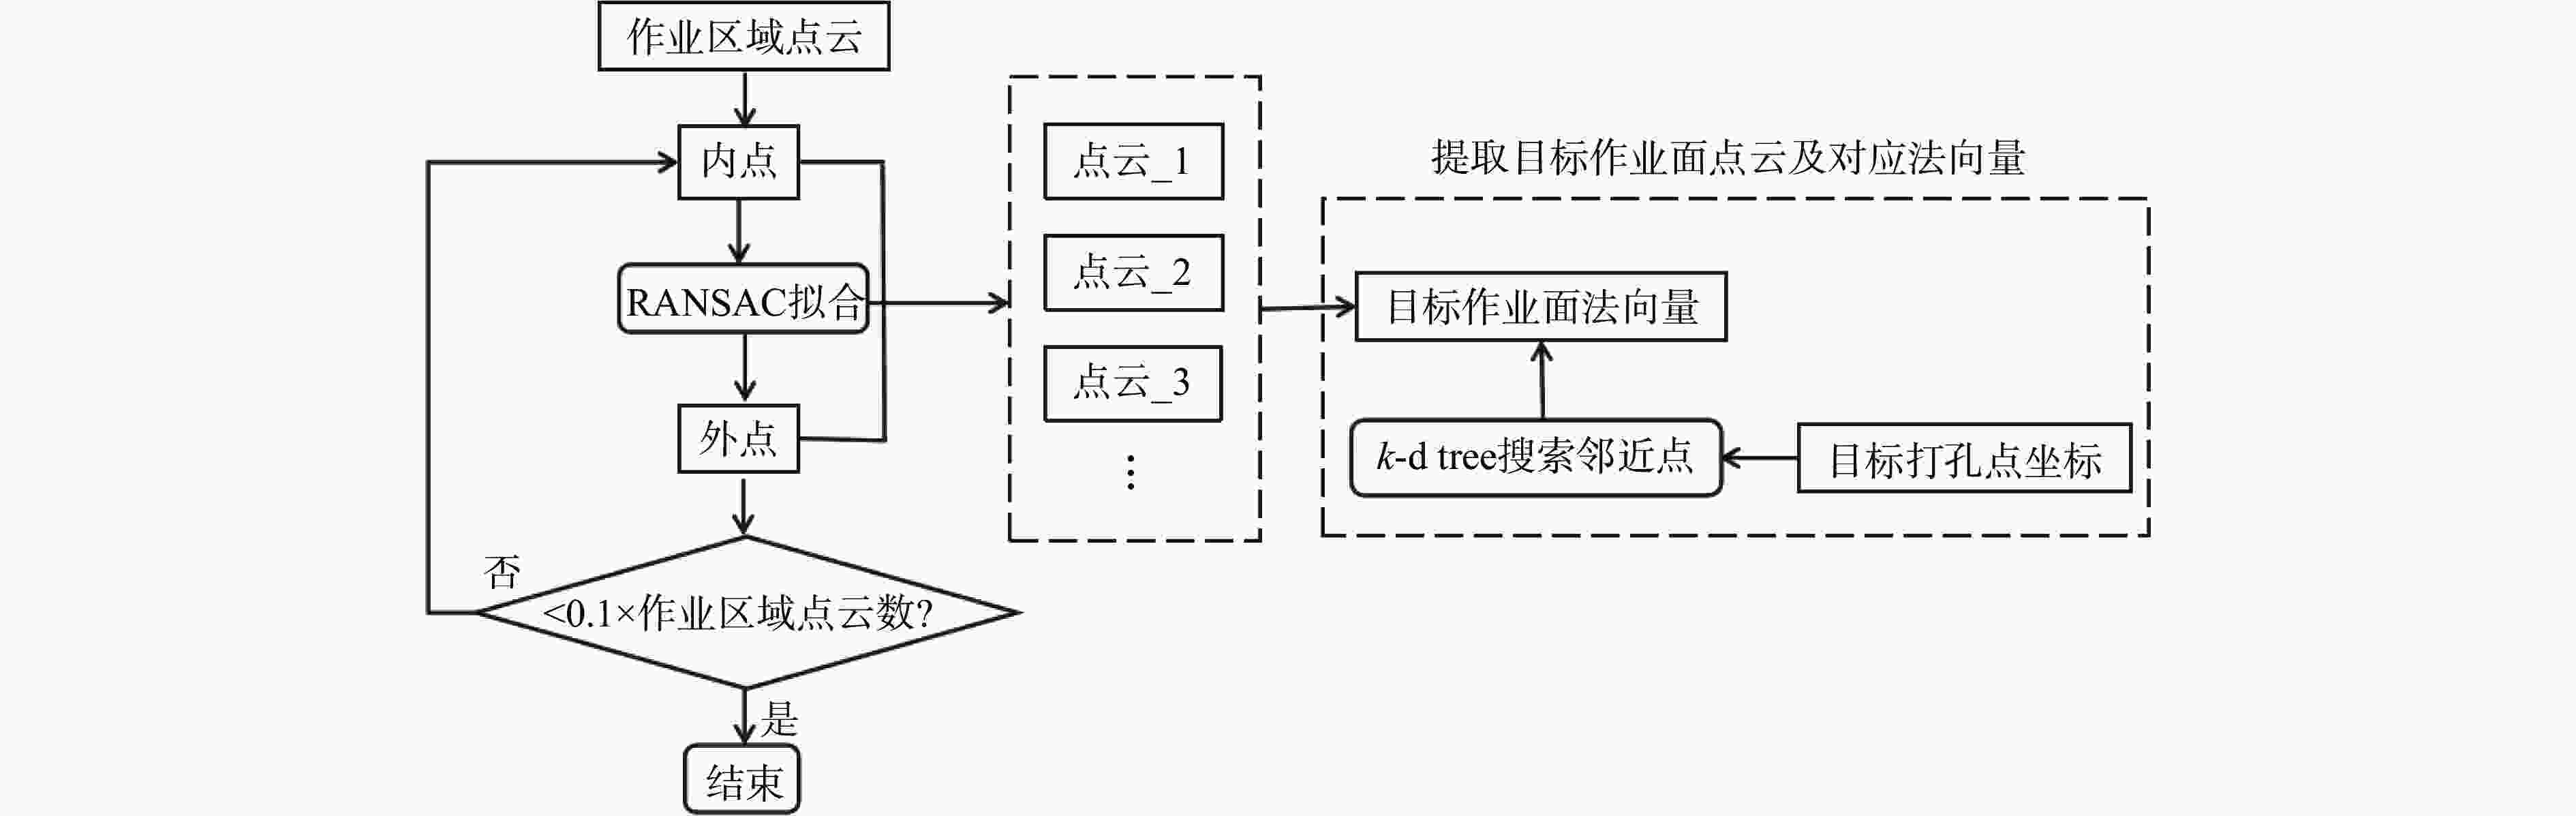
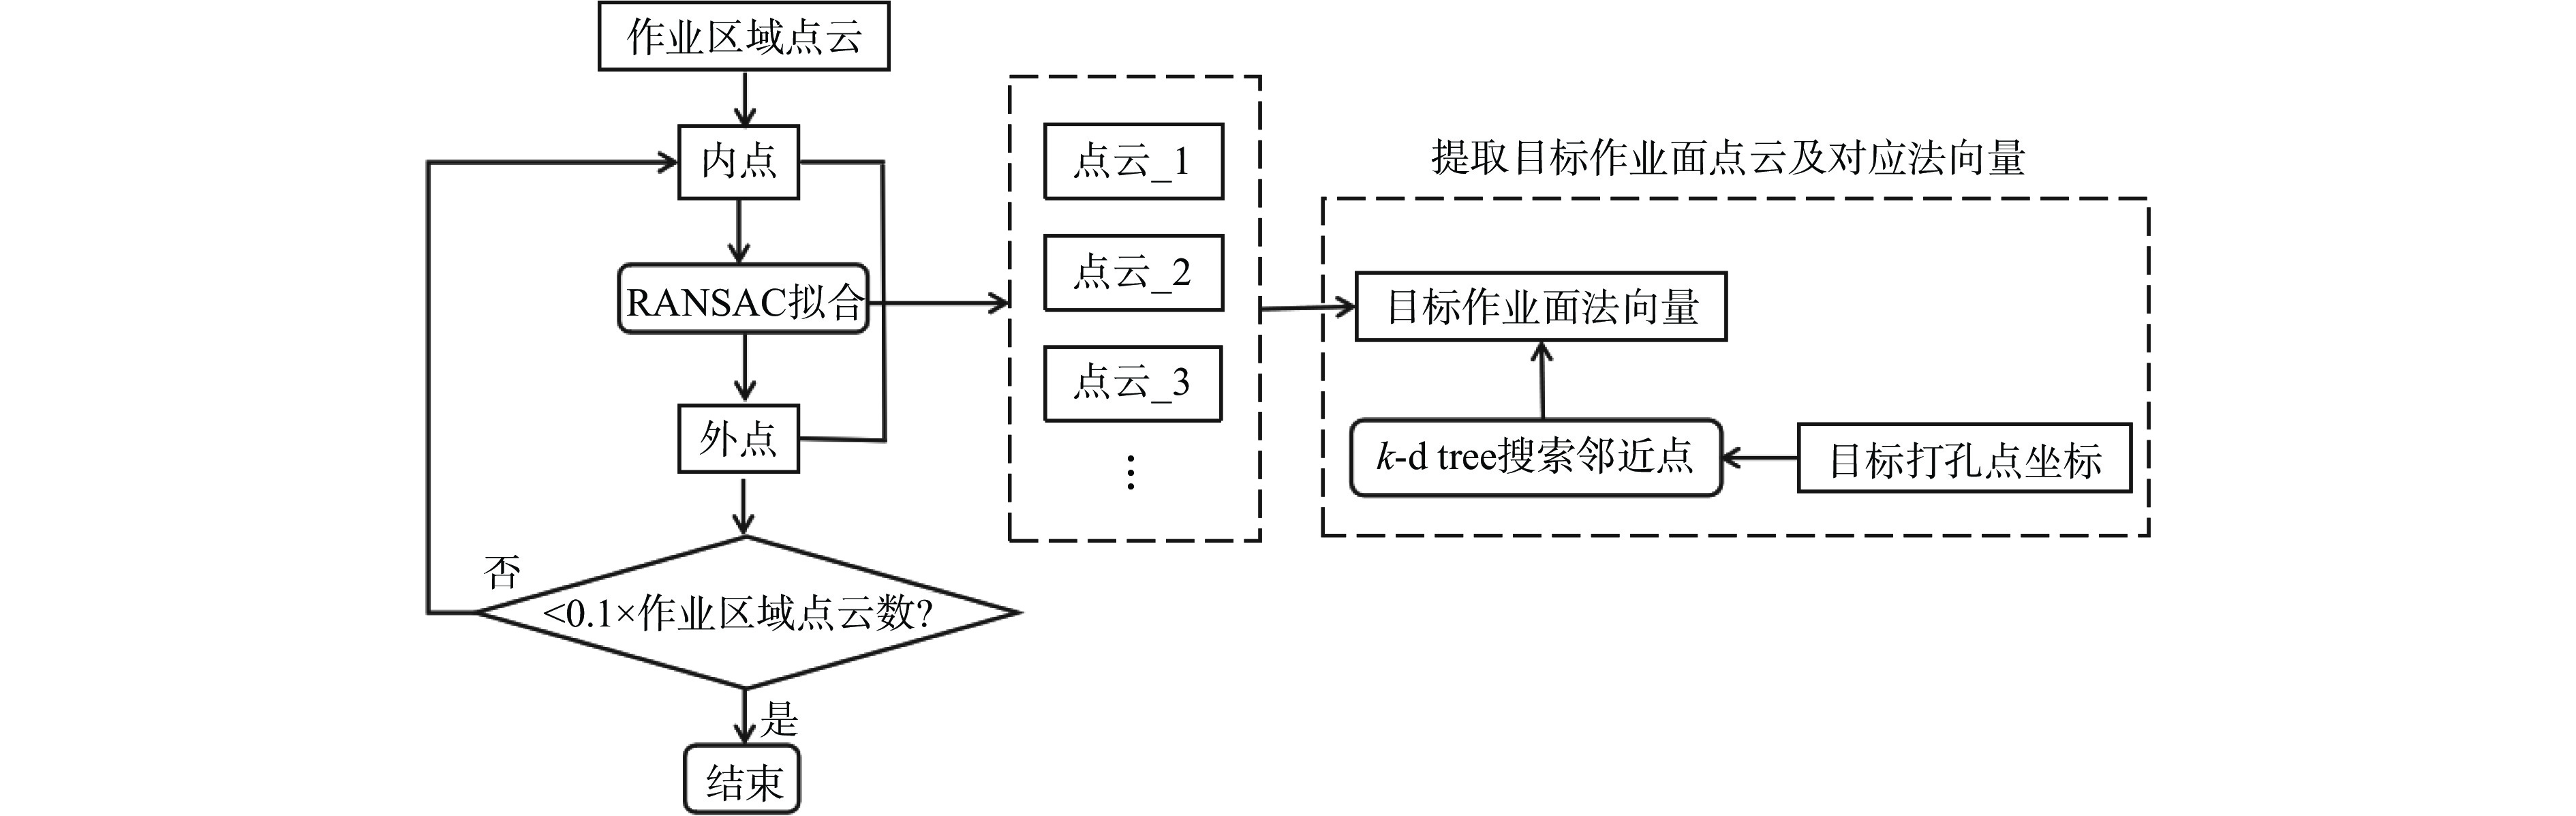
图 3 多平面点云拟合分割流程图
Figure 3. Flow chart of multi-plane point cloud fitting and segmentation
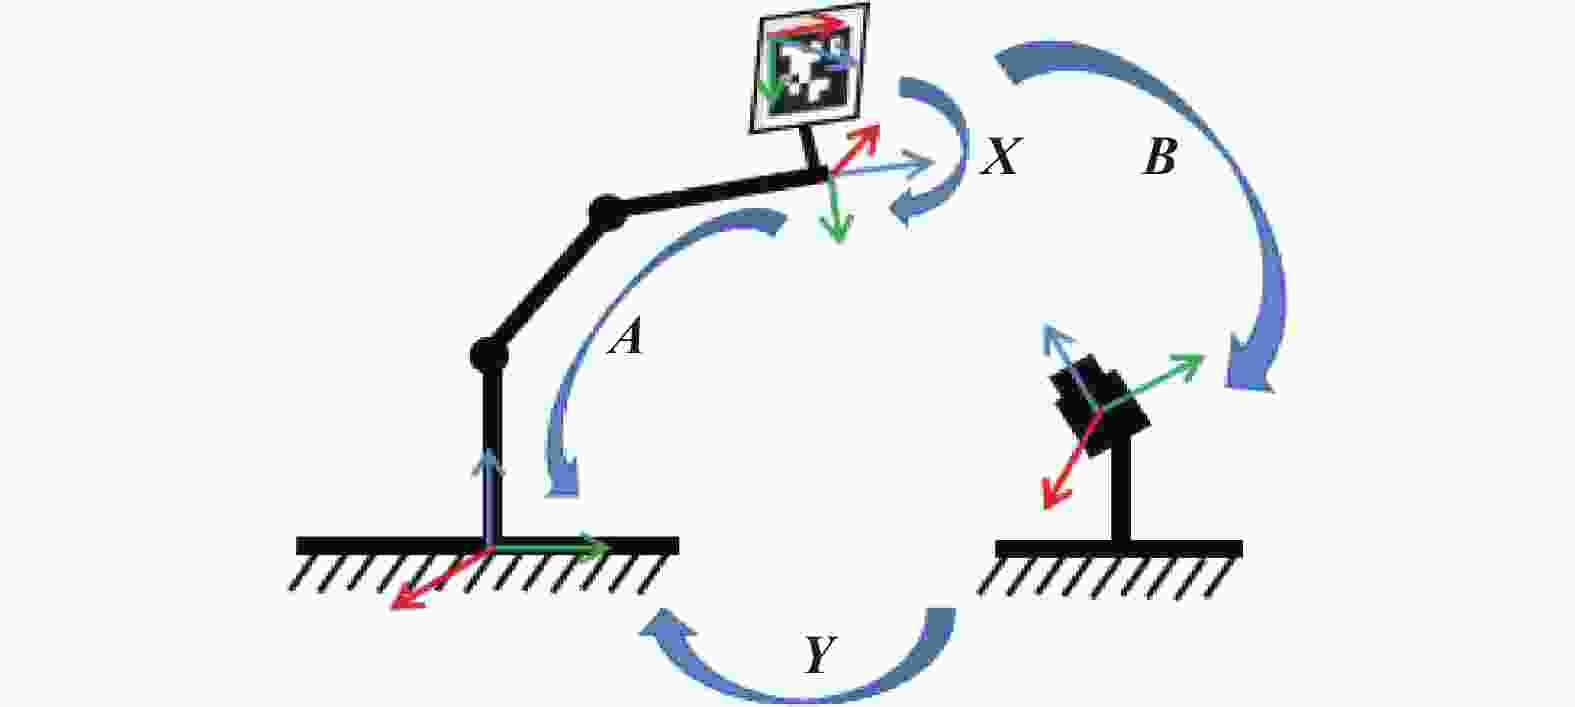
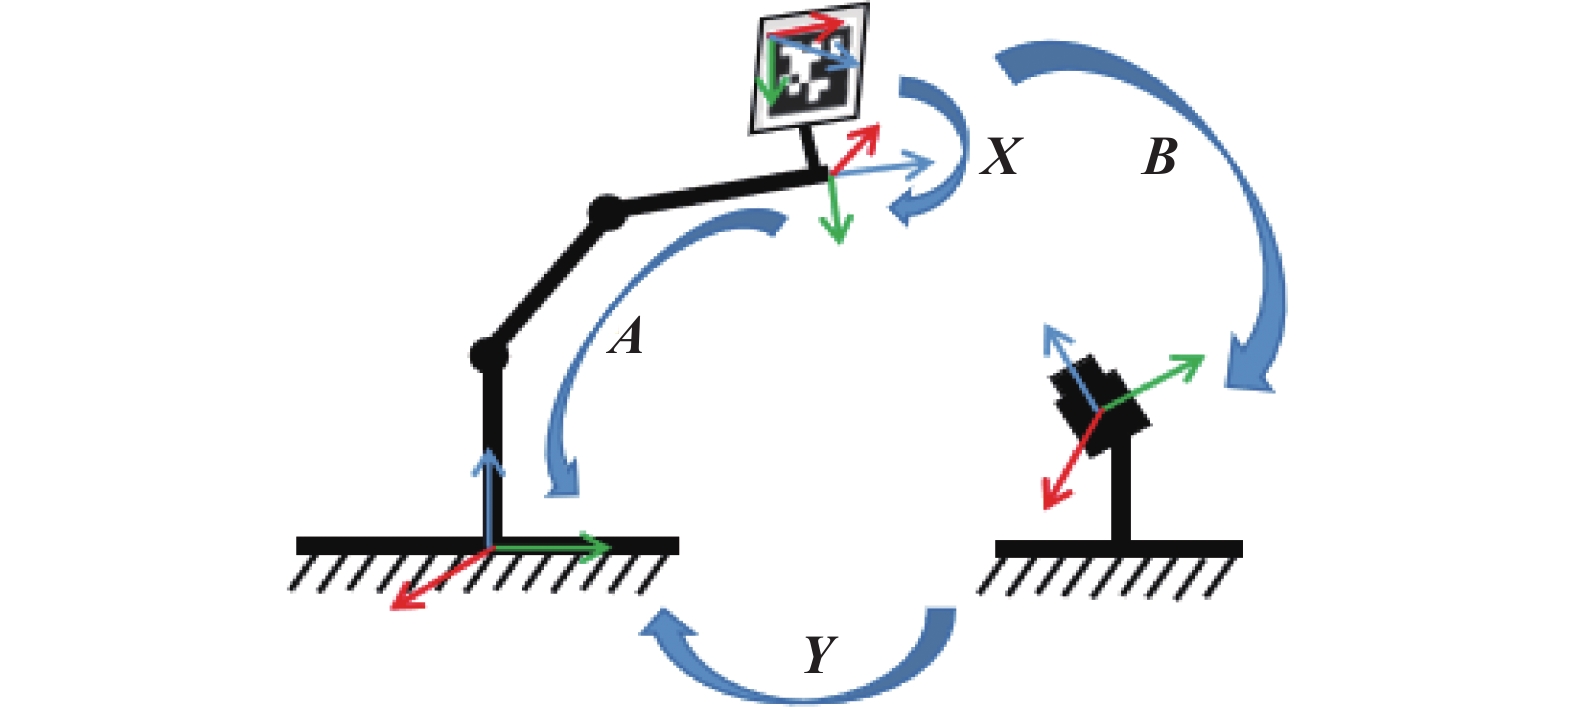
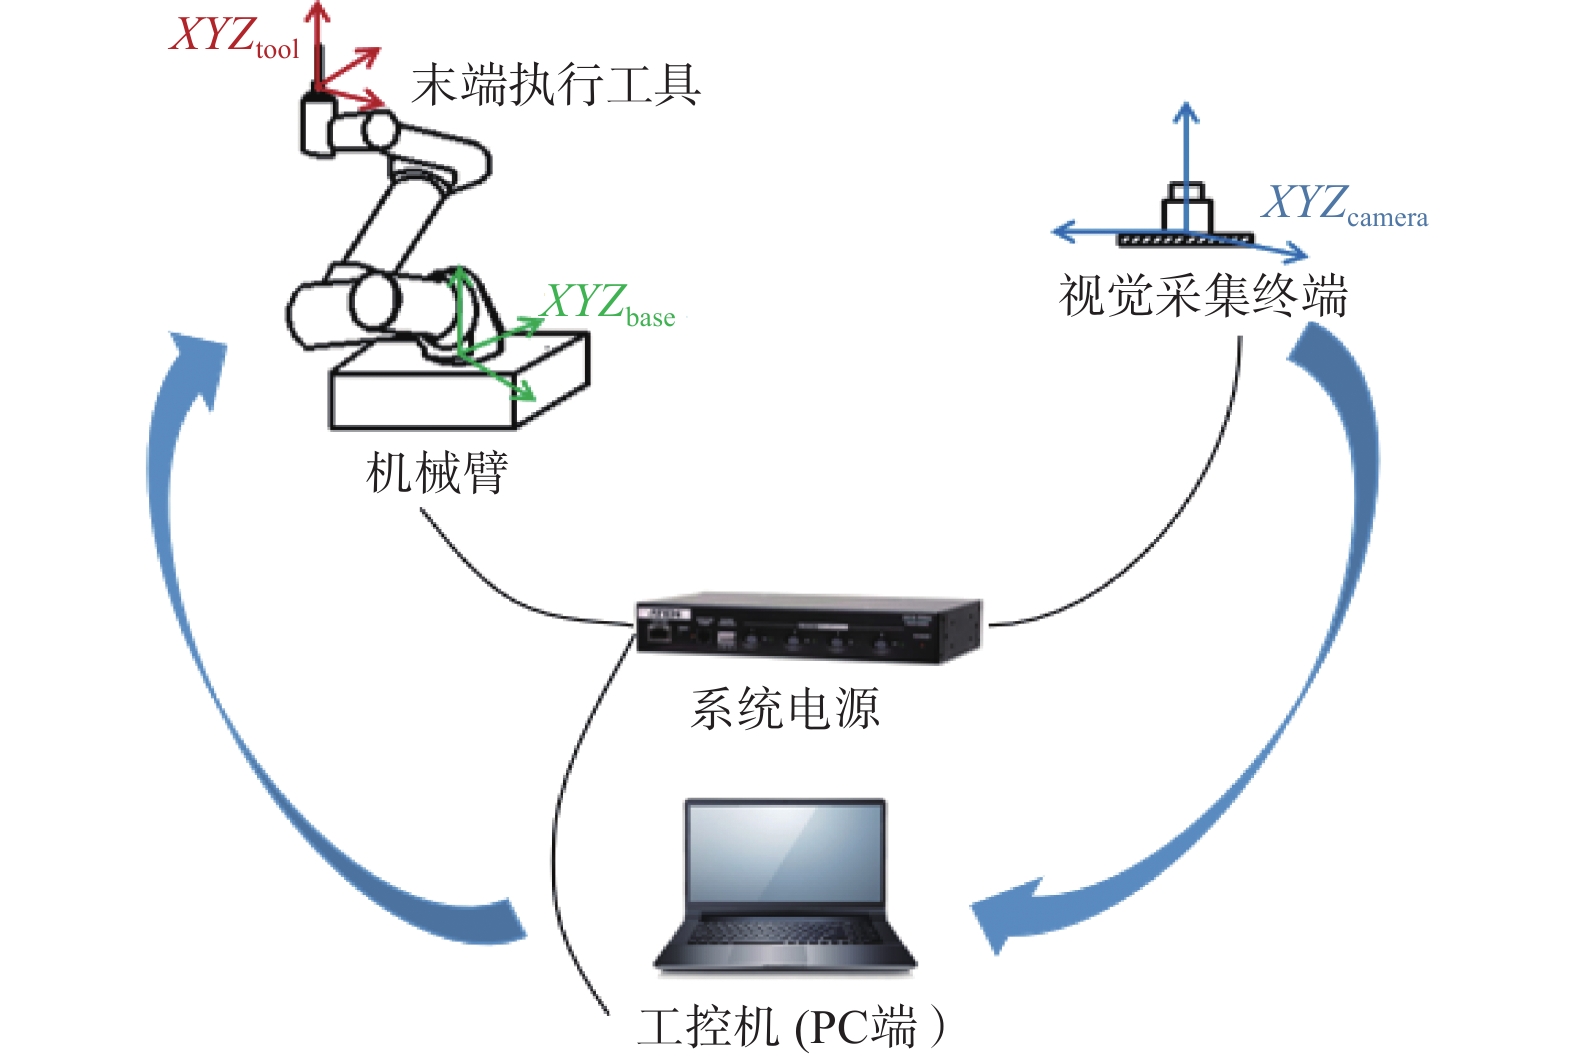
图 4 外参标定坐标转换关系图
Figure 4. Diagram of coordinate transformation relationship for extrinsic parameter calibration
表 1 6组试验数据
Table 1. Data of 6 groups of experiments
项目 第1组 第2组 第3组 第4组 第5组 第6组 $ {{\mathrm{RPY}}}_{{\mathrm{s}}\_ {\mathrm{b}}}/({^{\circ}}) $ w 13.551 18.696 10.921 −8.380 −24.311 30.196 p −3.949 −17.357 −34.048 8.104 −3.031 −39.751 r 97.105 106.117 114.250 106.298 108.532 100.261 $ {\boldsymbol{F}}_{{\mathrm{s}}\_ {\mathrm{b}}} $ x 0.241 0.386 0.399 −0.179 −0.375 0.593 y −0.038 −0.183 −0.423 0.093 −0.177 −0.454 z 0.970 0.904 0.814 0.979 0.910 0.665 $ {\boldsymbol{F}}_{{\mathrm{R}}\_ {\mathrm{c}}} $ x 0.277 0.386 0.367 −0.183 − 0.368 0.577 y −0.044 −0.203 −0.431 0.122 −0.621 −0.481 z 0.960 0.900 0.824 0.976 0.916 0.645 $ {\boldsymbol{F}}_{{\mathrm{R}}\_ {\mathrm{b}}} $ x 0.279 0.398 0.393 −0.190 −0.357 0.605 y −0.048 −0.199 −0.426 0.089 −0.204 −0.459 z 0.959 0.896 0.815 0.978 0.912 0.635 $ {\theta }_{\mathrm{sb-Rb}}/({^{\circ}}) $ 2.355 1.228 0.374 0.687 1.881 1.777  下载: 导出CSV
-
[1] 楼阿莉. 国内外自动钻铆技术的发展现状及应用[J] . 航空制造技术, 2005(6): 50 − 52. doi: 10.3969/j.issn.1671-833X.2005.06.008 [2] Olsson T, Haage M, Kihlman H, et al. Cost-efficient drilling using industrial robots with high-bandwidth force feedback[J] . Robotics and Computer-Integrated Manufacturing, 2010, 26(1): 24 − 38. doi: 10.1016/j.rcim.2009.01.002 [3] 薛汉杰, 张敬佩. 蒙皮类部件钻孔法向的测量和调整[J] . 航空制造技术, 2010(23): 60 − 62,66. doi: 10.3969/j.issn.1671-833X.2010.23.010 [4] 张晋, 周新房, 乔顺成, 等. 一种机器人末端制孔接触式法向找正技术研究[J] . 测控技术, 2020, 39(4): 49 − 52. doi: 10.19708/j.ckjs.2020.04.010 [5] 李鹏程, 李明宇, 郑炜, 等. 基于接触式压力脚的机器人制孔法向检测与调姿方法[J] . 计算机集成制造系统, 2023, 29(3): 731 − 739. doi: 10.13196/j.cims.2023.03.004 [6] 徐鹏. 面向飞机自动化装配的接触式法向找正技术研究[D] . 南京: 南京航空航天大学, 2021. [7] 公茂震, 袁培江, 王田苗, 等. 航空制孔机器人末端垂直度智能调节方法[J] . 北京航空航天大学学报, 2012, 38(10): 1400 − 1404. doi: 10.13700/j.bh.1001-5965.2012.10.013 [8] Gao Y H, Wu D, Nan C G, et al. Normal direction measurement in robotic drilling and precision calculation[J] . The International Journal of Advanced Manufacturing Technology, 2015, 76(5/6/7/8): 1311 − 1318. doi: 10.1007/s00170-014-6320-7 [9] 张赢, 丁红昌, 赵长福, 等. 基于多激光传感器装配的自由曲面法线找正方法研究[J] . 中国光学, 2021, 14(2): 344 − 352. doi: 10.37188/CO.2020-0205 [10] Tian W, Zhou W X, Zhou W, et al. Auto-normalization algorithm for robotic precision drilling system in aircraft component assembly[J] . Chinese Journal of Aeronautics, 2013, 26(2): 495 − 500. doi: 10.1016/j.cja.2013.02.029 [11] Gao R, Yang X D, Yu H B, et al. Fringe-projection-based normal direction measurement and adjustment for robotic drilling[J] . IEEE Transactions on Industrial Electronics, 2020, 67(11): 9560 − 9570. doi: 10.1109/TIE.2019.2952791 [12] 张宏伟, 张国雄, 秦鹏, 等. 双目视觉检测技术在自由曲面测量中的应用[J] . 机械工程学报, 2004, 40(7): 110 − 113. doi: 10.3321/j.issn:0577-6686.2004.07.022 -

 下载:

 点击查看大图
图(6) / 表(1)
计量
- 文章访问数: 11
- HTML全文浏览量: 6
- PDF下载量: 1
- 被引次数: 0
